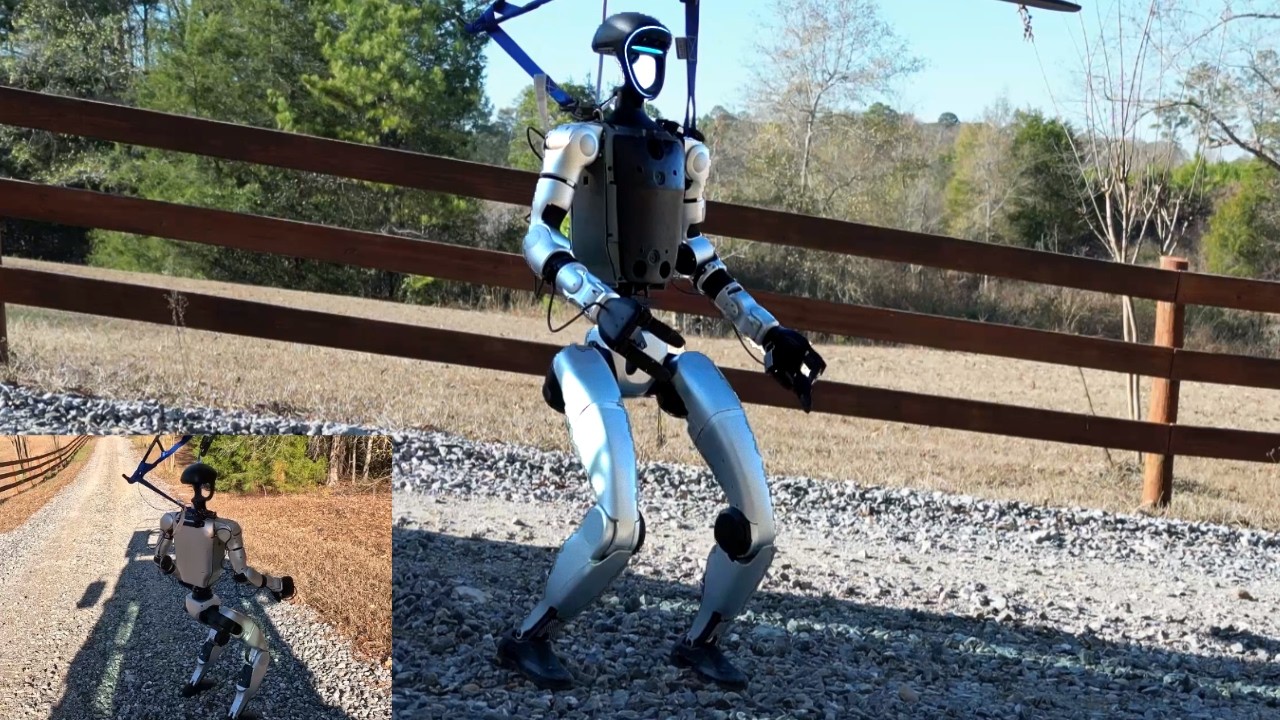
This page features a video demonstrating the process of training a Unitree G1 humanoid robot to walk using reinforcement learning techniques. The training employs mjlab and the Proximal Policy Optimization (PPO) algorithm to enable the robot to walk both indoors and outdoors. Additional resources related to neural networks and community engagement, such as memberships and social media links, are also mentioned.
NovaTube News acts as a platform aggregating publicly available videos from YouTube, including this training content. The site collects minimal technical information to improve user experience and uses only essential cookies. Video playback is handled through YouTube links, and the platform complies with privacy regulations, including GDPR, without targeting children under 13. Users can contact the site for privacy-related inquiries.